Postdoctoral Scholar · UC Santa Cruz
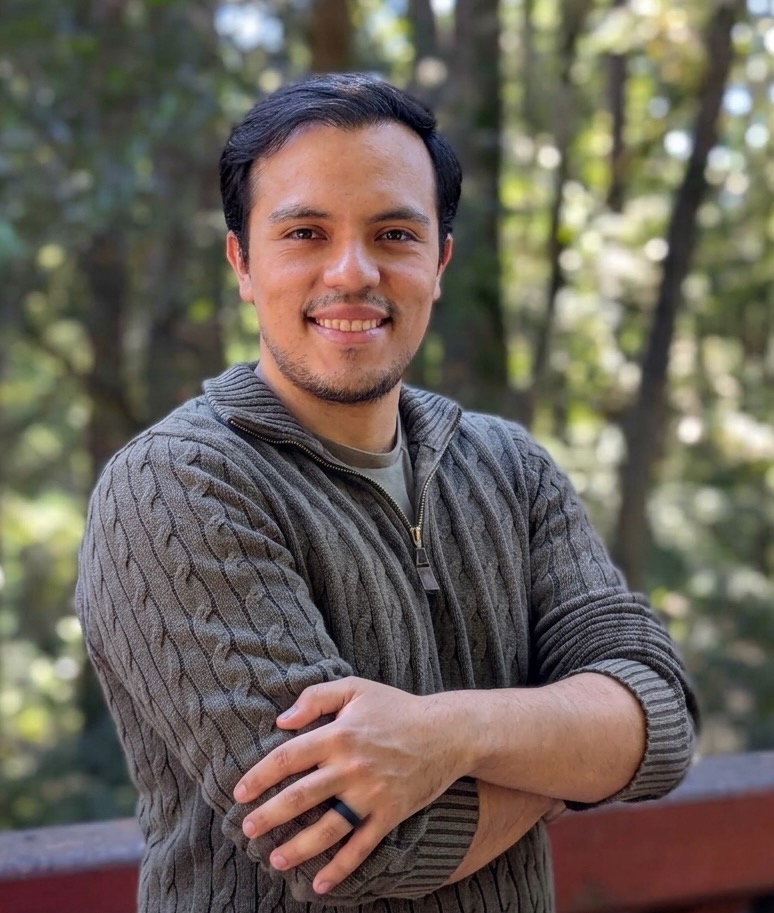
Daniel E. Ochoa
I develop rigorous theoretical tools to abstract, interpret, and understand real engineering systems as they evolve over time. From that understanding, I design robust and reliable solutions to control and decision-making problems in autonomous systems, robotics, networks, and learning.
I work at the Hybrid Systems Laboratory, University of California, Santa Cruz.
Recent news
Last two years- 07/2026
Three papers to appear at CDC 2026
“Solution Sets of Geometric Hybrid Systems”, with P. P. Jirwankar and R. G. Sanfelice. “Sufficient Conditions for Set Invariance using Multiple Barrier Functions”, first-authored by P. P. Jirwankar. “Pointwise Minimum-Norm Control Laws for a Class of Stochastic Hybrid Systems”, first-authored by C. A. Montenegro.
- 05/2026
HSRU Postdoctoral Fellowship
Named an HSRU Postdoctoral Fellow.
- 02/2026
Paper accepted
“Prescribed-Time and Hyperexponential Concurrent Learning with Partially Corrupted Datasets” to appear in Nonlinear Analysis: Hybrid Systems.
- 01/2026
Two papers accepted
“Neural Hybrid Equations: Models, Basic Properties, and Approximation Results” at ACC 2026, and “On Input-to-State Stability for a Class of Stochastic Hybrid Systems” at HSCC 2026; the latter led by C. A. Montenegro.
- 11/2025
Robert Skelton Best Ph.D. Dissertation Award
Awarded by UC San Diego.
- 07/2025
Two papers at CDC 2025
“On Non-Euclidean Contraction Theory for Constrained Differential Inclusions”, and “Geometric Hybrid Dynamical Systems on Intrinsic Manifolds, Part II”, led by P. P. Jirwankar.
- 04/2025
Paper at L4DC 2025
“Deep Source-Seekers with Obstacle Avoidance: Adaptive Hybrid Control with Vision Transformers”, led by C. Zhang.
- 02/2025
Paper accepted
“On the Instability of Nesterov’s ODE under Non-Conservative Vector Fields” in IEEE Control Systems Letters.
- 10/2024
New postdoctoral position
Joined the Hybrid Systems Laboratory at UC Santa Cruz.
- 09/2024
PhD defense
Successfully defended my PhD dissertation at UC San Diego.
- 08/2024
Paper accepted
“Decentralized Concurrent Learning with Momentum and Restart” in Systems and Control Letters.
- 07/2024
IFAC Young Author Award
Received at the 8th IFAC Conference on Analysis and Design of Hybrid Systems.
- 07/2024
Paper accepted
“Robust Global Optimization on Smooth Compact Manifolds” in Automatica.
Selected publications
All- 2026
Prescribed-Time and Hyperexponential Concurrent Learning with Partially Corrupted Datasets: A Hybrid Dynamical Systems Approach
Nonlinear Analysis: Hybrid Systems
- 2025
Robust Global Optimization on Smooth Compact Manifolds via Hybrid Gradient-Free Dynamics
Automatica
- 2023
Momentum-Based Nash Set Seeking over Networks via Multi-Time Scale Hybrid Dynamic Inclusions
IEEE Transactions on Automatic Control